Ask a facilities manager for the current condition of every path light, bench, fence line and drainage grate across a large campus, and the honest answer is an estimate assembled from complaints. Estates are too large for daily human rounds and too varied for fixed sensors, so condition knowledge arrives late and by accident - the broken light reported by a student, the flooded path discovered by the event it ruins. Environmental patrol exists to replace that accident with a record: the whole estate, observed on a schedule, compared against itself over time.
The Condition Record Nobody Has
An autonomous patrol robot produces that record as a by-product of walking. The round is fixed, the viewpoints are fixed, and so every observation is comparable with the last one - the same light, from the same position, each night. Change becomes visible because everything else is held constant.
What an Environmental Round Checks
The checklist is deliberately mundane, because estates fail mundanely: path and area lighting working or dark; litter accumulation at bins and gathering points; damaged or moved fixtures - benches, signs, barriers, fencing; standing water, erosion and path surface damage; vegetation encroaching on paths and sightlines; gates and access points in their expected state. Each item is a photograph, a position and a timestamp, captured at the pace of a walking round that no staffing model can sustain nightly across a large site.
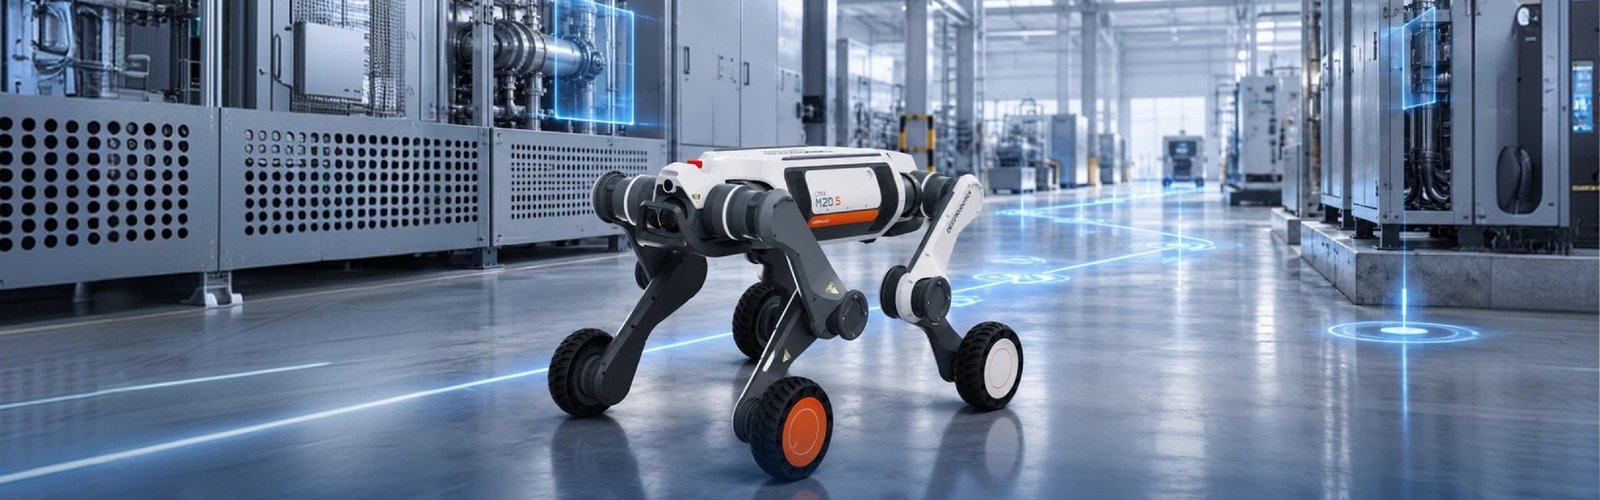
Booster quadrupeds already work this pattern in campus service - scheduled patrol at a partner university, with an embodied navigation system keeping the robot on route and its observations located. The environmental variant simply points the same machinery at the estate's condition rather than its security, and in most deployments the two rounds merge: one walk, two reports.
From Findings to Work Orders
A patrol that produces footage produces nothing. The environmental round is designed backwards from the maintenance workflow: findings are classified at capture (lighting, waste, damage, water, vegetation), packaged with position and imagery, and delivered into the channels the maintenance team already uses - so a dark path light becomes a ticket with a map pin, not a video someone must watch. Repeat findings escalate automatically: the litter hotspot photographed nightly becomes evidence for a bin relocation decision, with data attached.
This is where the platform layer matters more than the robot. Booster's operation and scheduling platform is the surface on which routes, rounds and findings are managed across a fleet - the robot is the sensor that walks; the platform is the system that remembers. Buyers should evaluate the report chain end to end, from a finding on the round to a closed ticket, before evaluating the machine's walking.
Why Legs Suit Grounds as They Are
Parks and campuses are the least machined landscapes in the built environment: grass, gravel, kerbs, steps, mud after rain, leaf-fall in season. Wheeled patrol platforms handle the paved fraction and strand at the first shortcut the round actually needs. Legged and wheeled-legged robots treat the estate as continuous terrain - the round crosses the lawn because the finding is on the lawn. That completeness is the product: a condition record with no paved-only blind spots.
Weather writes the honest footnote: heavy rain and ice shrink any platform's envelope, and a credible programme defines weather rules in advance rather than discovering them. Within those rules, the scheduled round runs in the dark hours when the estate is empty - which is precisely when lighting checks mean anything.
Starting an Environmental Patrol
Choose one estate zone, one checklist of a dozen items, one season. Baseline the round with the maintenance team walking it alongside the robot, agree the finding format with the people who will close the tickets, and let a season of records argue for extension. The estates that adopt environmental patrol rarely abandon it, because the condition record - once it exists - becomes impossible to un-want.