Power facilities are unforgiving buyers: the rounds are real, the readings matter, and a robot that misses them is worse than none. A quadruped robot for power inspection can be an excellent purchase - or an expensive mascot - depending entirely on how the evaluation is run. This guide, written for power inspection teams, orders the buying process the way deployments actually succeed: route first, readings second, robot third.
Start With the Route and the Reading List
Before looking at any robot, document the round as it exists today: its length and surfaces, the inspection points in order, and at every point the reading required - a gauge photographed, a thermal image of a connection, a switch state verified, a sound or partial-discharge check. Note the environment honestly: indoor switch rooms, outdoor yards, gravel, cable trenches, stairs between levels. This document is your specification. Every vendor claim that follows gets tested against it, and any robot - ours included - that cannot cover your route and reading list is the wrong robot, however impressive its demonstration.
Match Payloads to Readings, Not Brochures
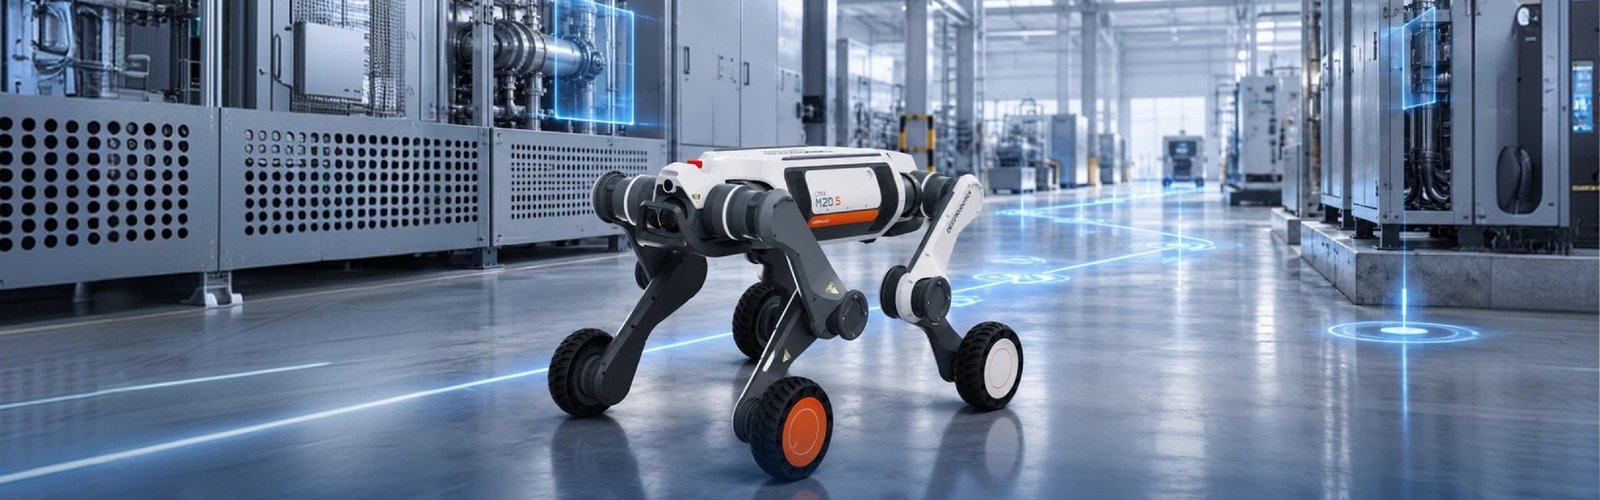
Inspection value is payload value. Visual cameras handle gauge reading, state verification and general condition. Thermal imaging - in our range, a dual-spectrum gimbal combining visible and thermal views - catches the hot connections and overheating components that precede failures. LiDAR builds the spatial model the navigation and change-detection rely on. Work through your reading list and mark which payload each reading needs; then check the platform carries that fit while walking your terrain. Booster's Jueying X30 is our flagship answer to this specification, but the method stands for any candidate: payloads follow readings, never the reverse.
Navigation and Repeatability at the Point
An inspection robot's core skill is boring excellence: arriving at the same point, in the same pose, capturing the same reading, round after round, so results can be compared over time. Evaluate navigation accordingly - route holding around obstacles and people, re-acquisition after disturbance, and above all point repeatability, because a thermal image taken from a different angle each week is data noise wearing a uniform. The X30-class platform's embodied navigation at Zhejiang University's campus patrol deployment, described in our case studies, shows the behaviour pattern to look for: scheduled, repeatable, reported.
The Data Has to Land Somewhere
Readings that stay on the robot are a hobby. Ask how inspection data leaves the platform: the operator view during the round, the report format afterwards, the integration path into maintenance and asset systems, and the alert behaviour when a reading crosses a threshold. A deployment succeeds when the maintenance team trusts the robot's round enough to act on it - which means the data workflow, exception handling and audit trail deserve as much evaluation time as the walking. Include your data team in the pilot design from the start, not at the handover.
Structure a Pilot You Can Judge
Close with pilot discipline. Define the acceptance criteria before the robot arrives: route completion rate, readings captured against the list, point repeatability sampled, interventions per round. Run the pilot on your hardest representative route, not the easiest - a robot that passes the easy yard tells you nothing about the substation. Agree what happens with exceptions and faults during the trial, and who signs the result. Booster scopes X30 pilots exactly this way with power customers, because a pilot designed to be passable by anyone is a pilot that decides nothing.
Preparing an evaluation or a pilot for a substation, plant or network facility? Compare the relevant product range and deployment scenarios to take the next step.