
RL Training Framework
Train whole-body policies with reinforcement learning - the pipeline behind competition-grade locomotion and ball skills.

Booster developer tools give humanoid robot developers a complete pipeline: a reinforcement learning framework for training locomotion and soccer skills, a virtual-physical simulation environment for large-scale training, and deployment and verification tools that bring policies onto the real Booster T1 and K1. This is the same toolchain class used to develop the walking, kicking, dribbling, disturbance-rejection and fall-and-get-up skills demonstrated in competition.

Train whole-body policies with reinforcement learning - the pipeline behind competition-grade locomotion and ball skills.
Virtual-physical simulation closes the gap between simulated training and real-robot behaviour, with deployment and verification support.
Tools, interfaces and course resources structured for university teams, research labs and competition developers.
| Offering Type | Developer tools + RL framework + simulation environment |
|---|---|
| Supported Robots | Booster T1, Booster K1 humanoid robots |
| Workflow | Policy training - simulation - deployment - verification |
| Licence / Delivery Scope | — |
Values shown as — are not stated in the published product literature; no estimates have been added.
Custom skill development on a documented humanoid platform.
Train and deploy soccer skills with the competition toolchain.
Course-ready development environment for embodied AI curricula.
| Item | Booster Developer Tools | Self-Assembled Open Tools |
|---|---|---|
| Robot Integration | Built for T1 / K1 hardware and actuators | Integration work falls on your team |
| Sim-to-Real | Virtual-physical simulation provided as one workflow | Separate simulators and transfer methods to combine |
| Support Path | Product team behind the platform | Community support only |
Open tools remain valuable for research; the integrated toolchain removes the integration burden so teams start from skills, not plumbing.
Each robot is packed for international transport in protective export packaging with shock and moisture protection, together with its charger, cables and user documentation. Palletising, wooden-crate reinforcement and sea / air / express freight options are confirmed per order in the quotation. Delivery schedules are confirmed in writing before order confirmation - no fixed lead time is published online.
The Booster T1 and Booster K1 humanoid robots.
Locomotion and skill policies - walking, kicking, dribbling, disturbance rejection, fall-and-get-up and agile motions are the demonstrated skill set.
Yes - a virtual-physical simulation environment supports policy training, deployment and verification (sim-to-real).


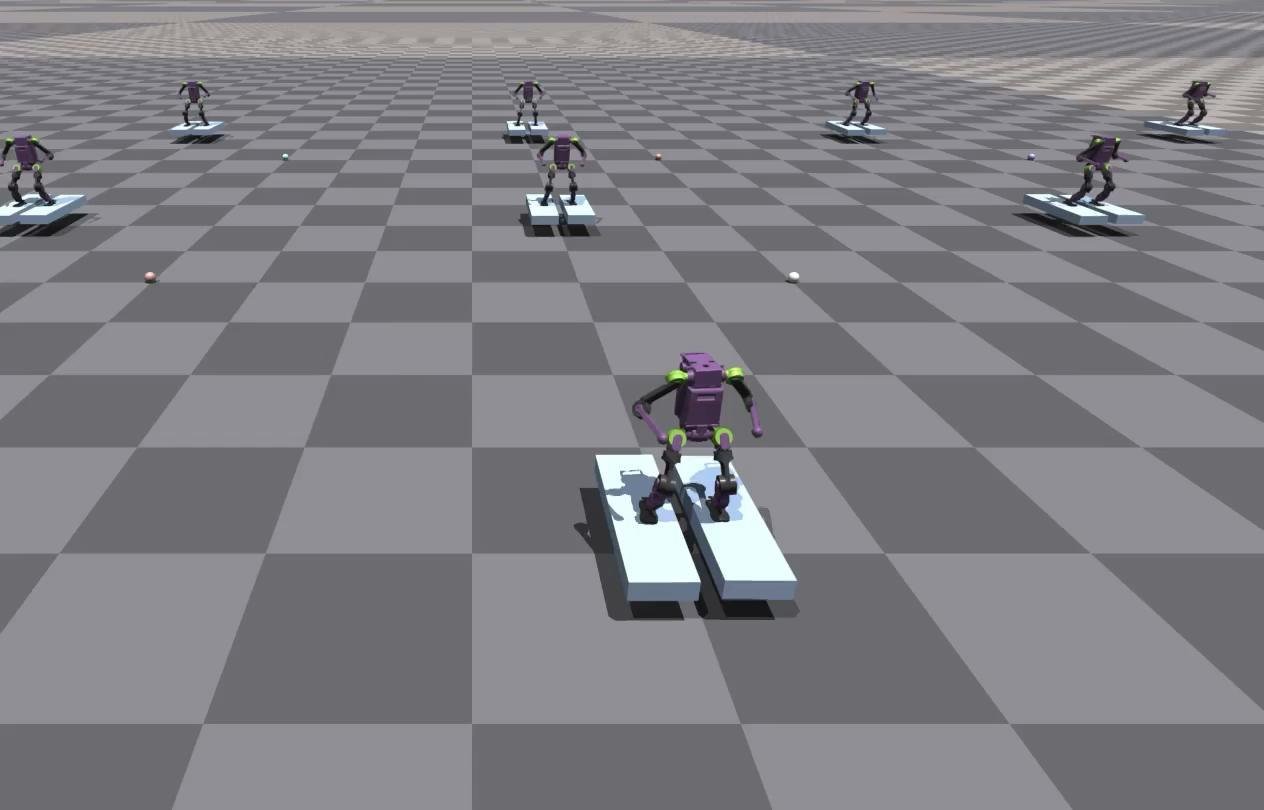
Simulation environment plus training ground for all robot forms.
Learn More →Compare specifications, deployment scenarios and integration requirements across the full range before you write your project specification.
Explore Products View Solutions